
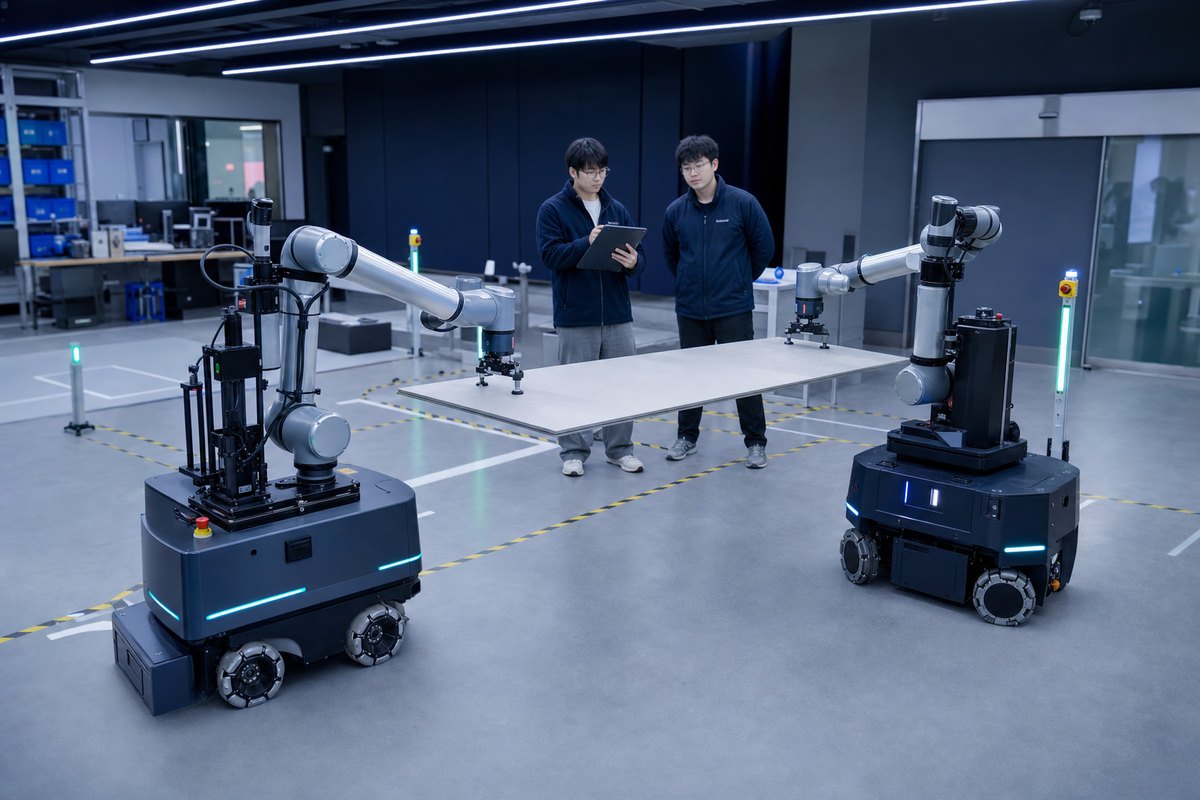
Concept visualnot one arm
not one arm
View the entire movement system.
We examine the arm, moving object, target object, battery/power source, communication, and safety structure as one system.
By combining mobile platforms and collaborative robots, joint transport of long objects, leader-follower control, path and safe stopping conditions are studied.
We examine the arm, moving object, target object, battery/power source, communication, and safety structure as one system.
For universities, research institutes, and companies considering operation and transportation automation, we verify platform combinations and interfaces and then verify limited scenarios.
Requirements/risk analysis, system configuration diagram, interface definition, experiment scenario, data log, result report.
Payload, center of gravity, stopping distance, safety scanner, emergency stop system, CAD/URDF/driver availability.