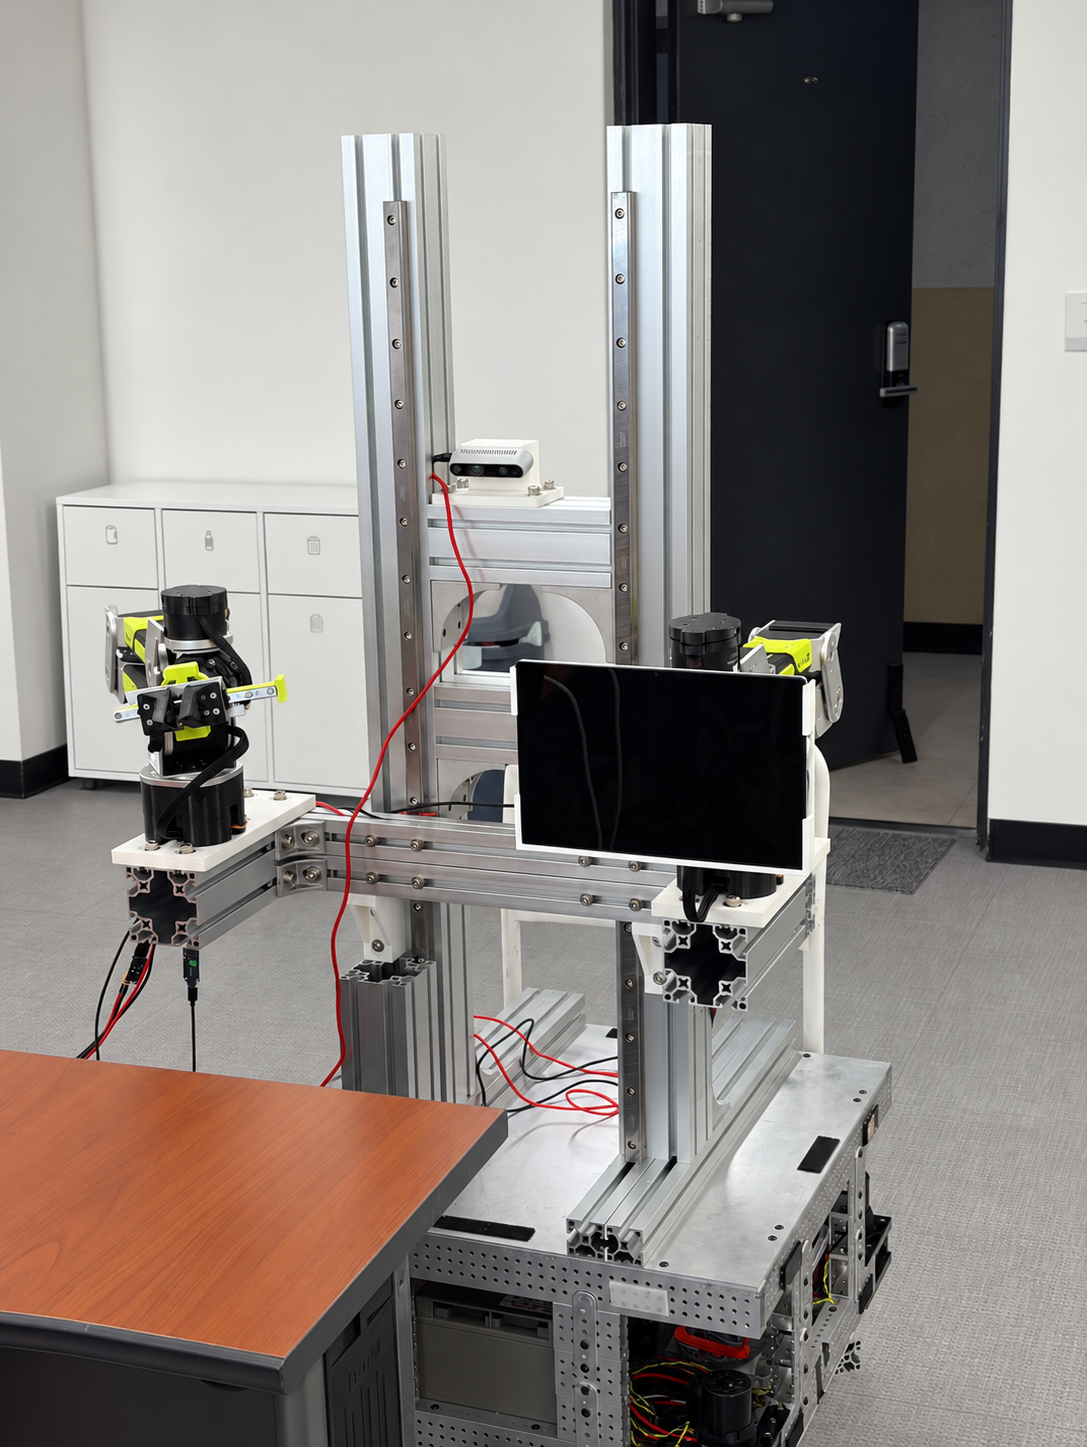
4-wheeled independent steering robot
It consists of a direct production type and a production delivery type, and expands research equipment such as lidar, cameras, and robot arms.
View product/delivery method →We propose separate commercialization paths for research platforms, autonomous driving/control verification, multi-robot operation, mobile manipulators, and service robots.
Check the research objectives, environment, safety conditions, and required results before the product name.

It consists of a direct production type and a production delivery type, and expands research equipment such as lidar, cameras, and robot arms.
View product/delivery method →
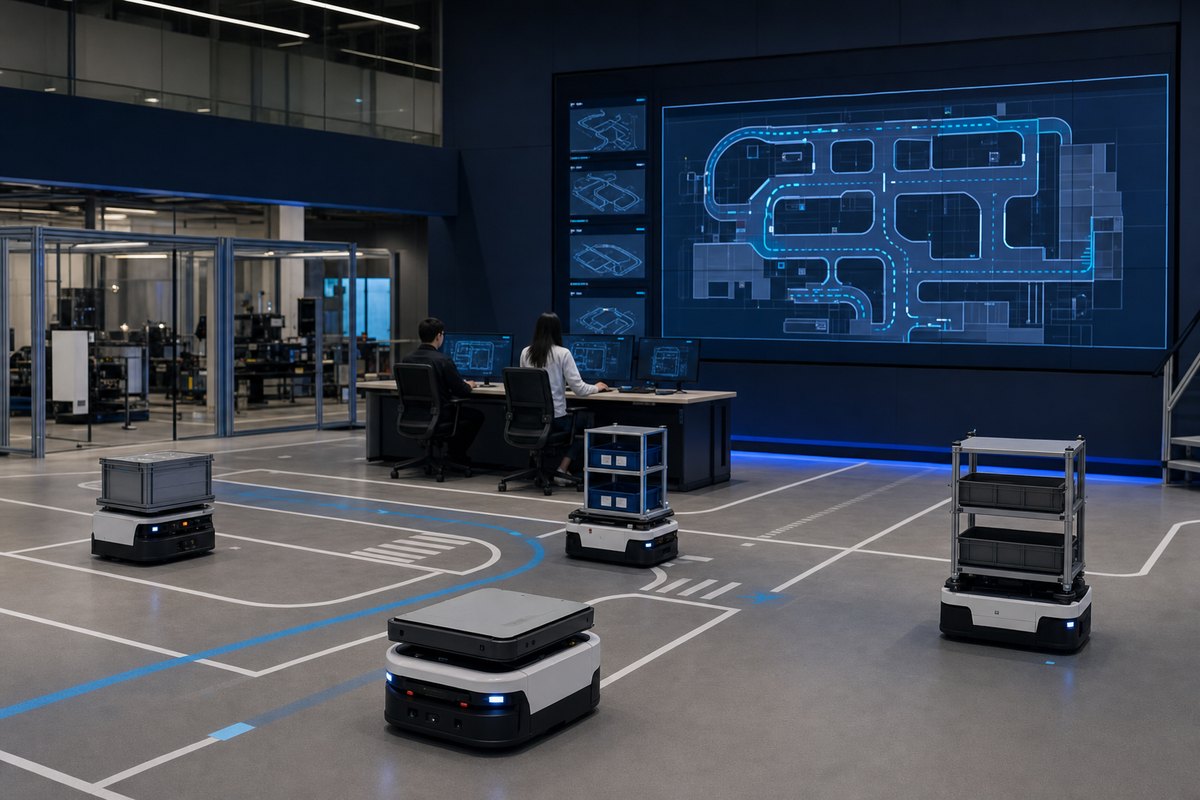
Covers path, collision, task planning, heterogeneous states, and digital twin visualization.
View Operations Research →
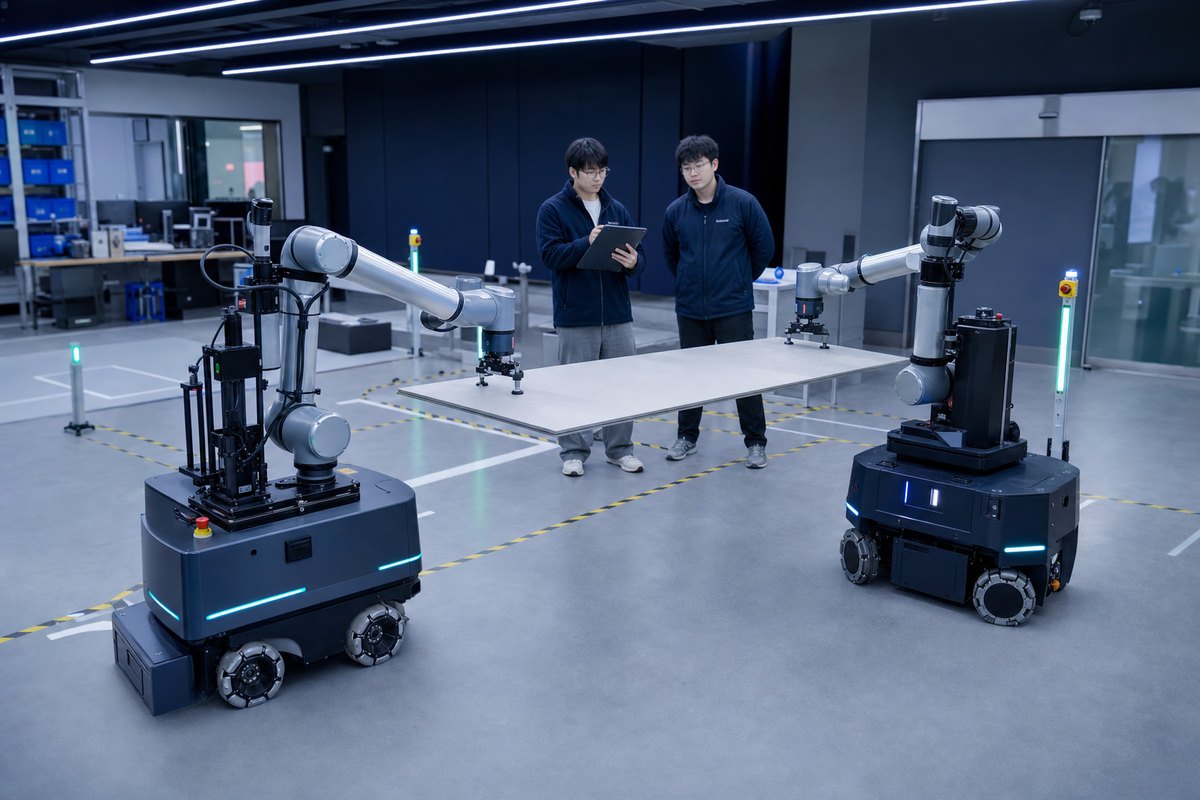
Combining mobile platforms and collaborative robots to verify joint transport, synchronization and safe stopping.
View research scope →
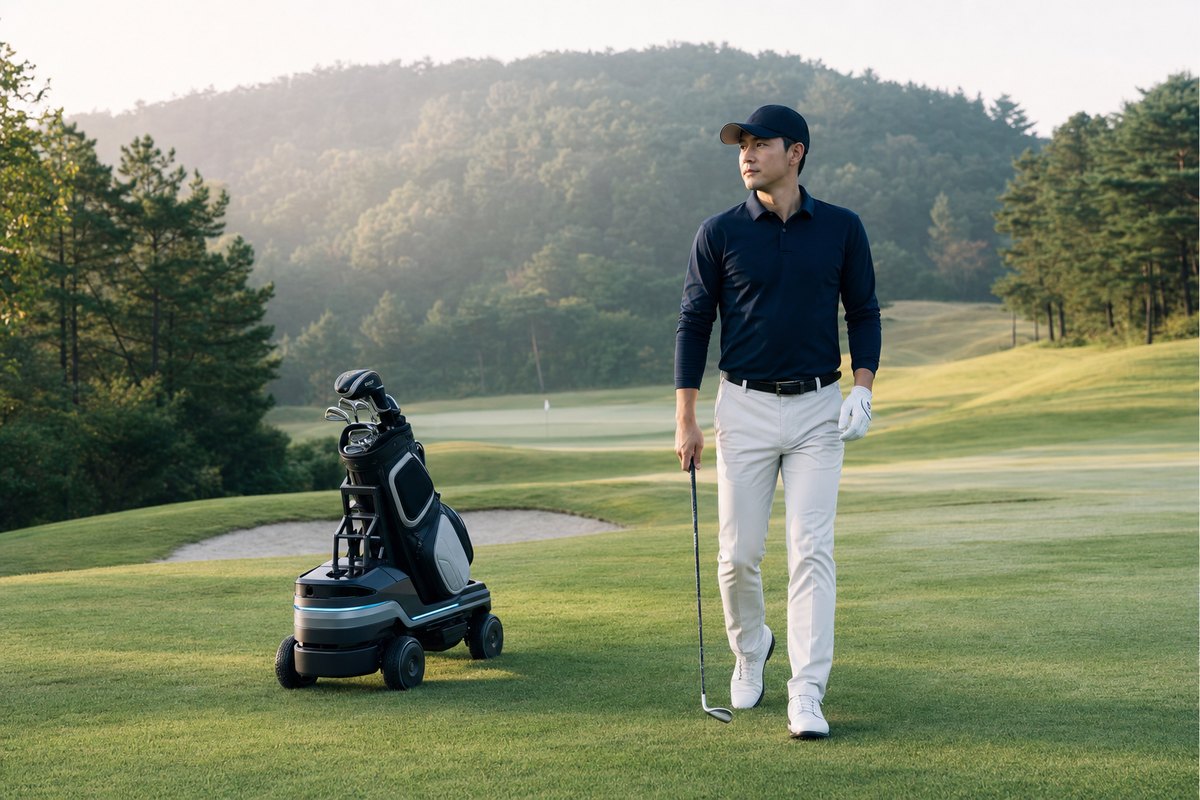
Examines unstructured terrain movement, user assistance, app/control and operational data connectivity.
View commercialization direction →Rather than promising prices and performance up front, we make clear the results the customer receives and the next judgment at each step.
Standard base, sensor, and control configurations and reproducible experiment documentation.
Defined field tasks, success indicators, safety conditions and results reports.
Proven BOM, software, operational tools and maintenance support range.
Linkage between purpose-specific robots and control/tasks, possibility of repeat operation.
If you tell us the research/field environment and required results, we can more quickly organize the scope of provision and exclusion.