
Concept visualNot a single success
Not a single success
View the entire flow.
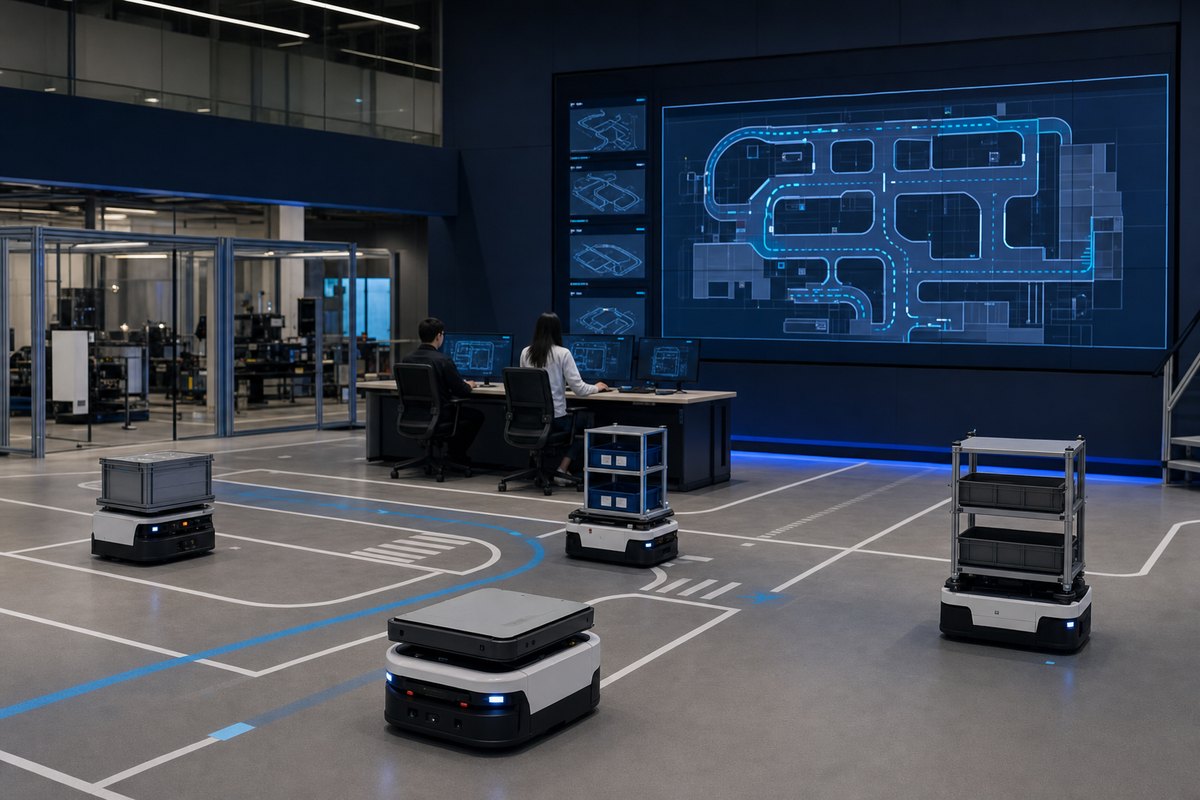
Check the path, collision, work plan, robot status, and site constraints together on the simulation and operation screen.
Rather than the number of robots per se, we measure collision waiting, mission completion, replanning, deadlock, and operator intervention together.
Check the path, collision, work plan, robot status, and site constraints together on the simulation and operation screen.
Verify operational hypotheses with limited number of robots and areas in logistics, manufacturing, and research environments. Actual equipment and research objectives are clearly distinguished at the proposal stage.
Scenario definition, configuration diagram, indicator baseline, experiment log, exception/intervention record, result report, and expansion conditions.
On-site safety certification, large-scale operational performance, and third-party equipment integration are not guaranteed without separate review.