University research lab/educational institution
Make it yourself,
Make it yourself,
Add a sensor,
A robot that expands through experimentation.
The 4-wheel independent steering mobility platform is designed to continue from assembly training to research on autonomous driving, sensor fusion, and mobile manipulation.
Direct production typeProduction delivery typeTechnical data providedSensor configuration consultation
price Separate inquiry · Discuss depending on purpose, sensor and top mounting configuration
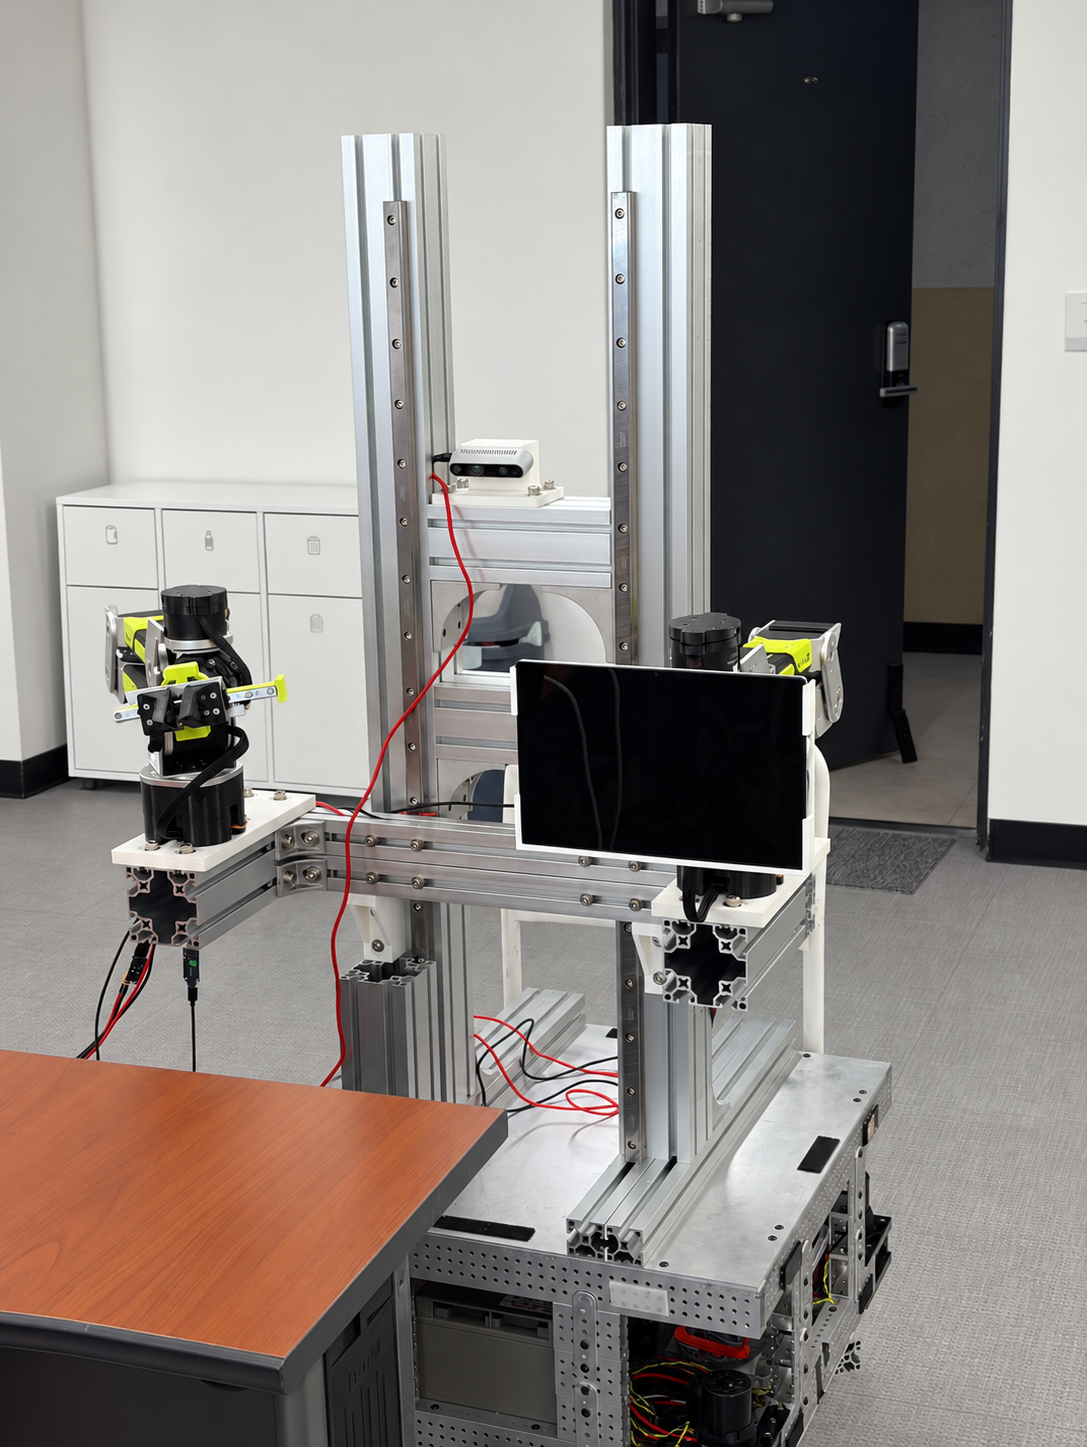
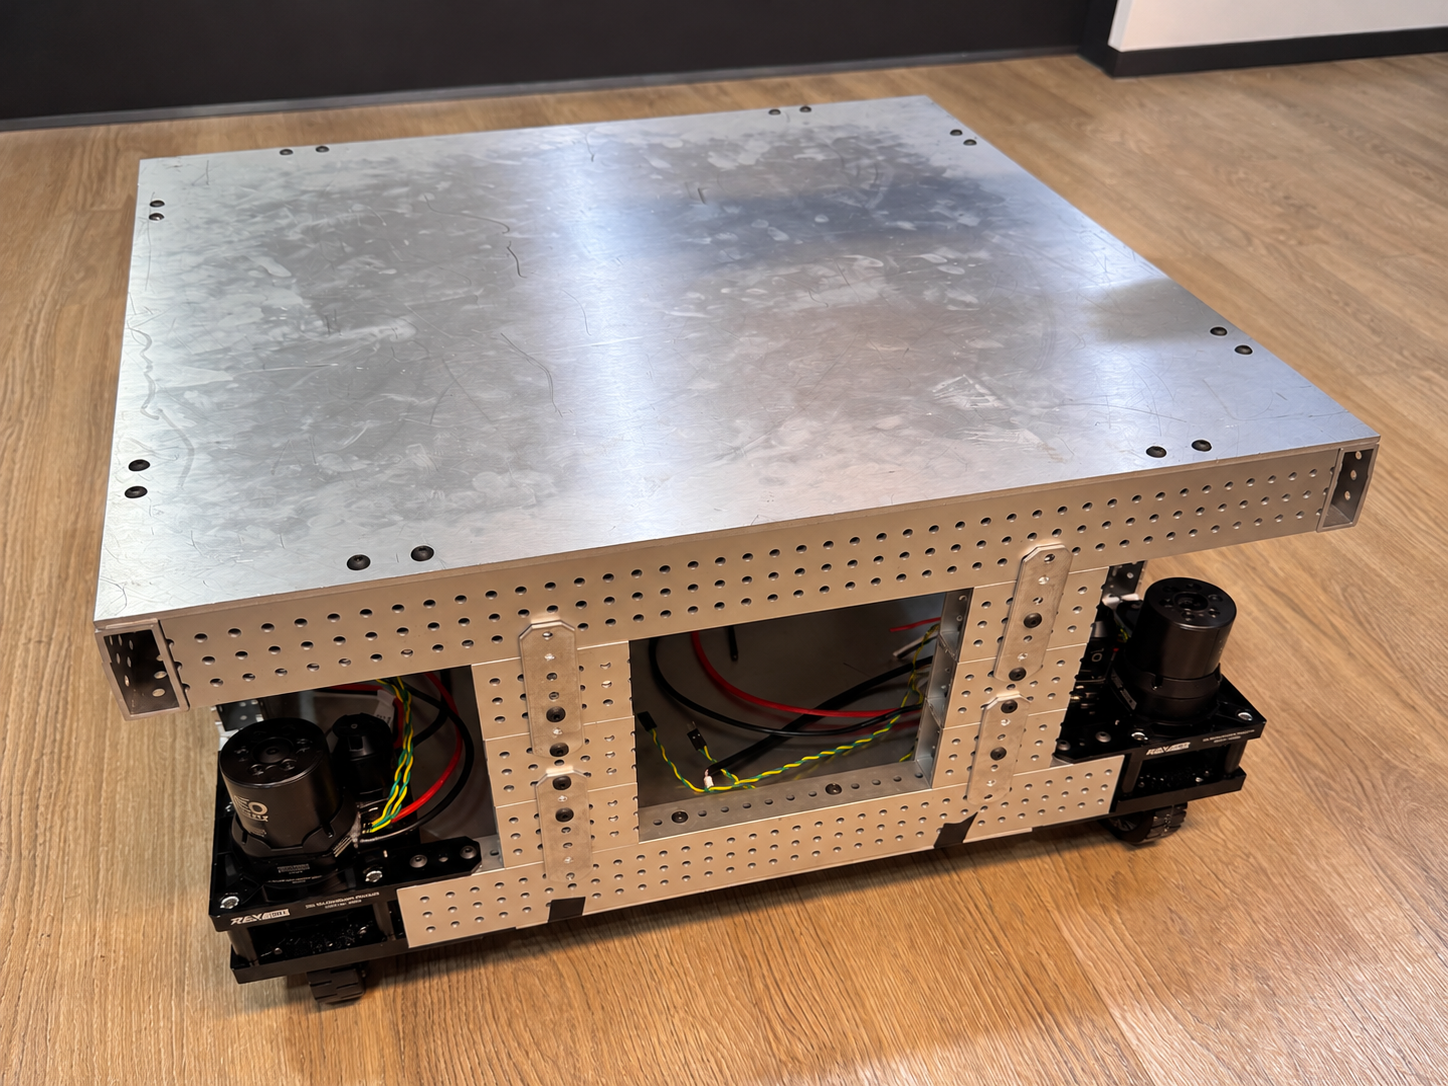
ACTUAL BUILD RECORDWith actual production and driving videos
With actual production and driving videos
We show you the readiness for delivery.
These are actual production photos and driving GIFs included in the presentation, not concept images. You can directly check diagonal driving, crab walk, pivot turn, and zero turn movements.
 diagonal driving
 crab walk
 pivot turn
 zero turn
TWO DELIVERY OPTIONSAccording to the class method and research schedule
According to the class method and research schedule
Choose an introduction method:
Whichever method you choose, we provide basic technical data necessary for understanding the platform and subsequent experiments.
Students assemble it themselves
Learn structure and control.
We discuss the composition and scope of technical data to enable step-by-step assembly in class, capstone, and club projects.
- Assembly sequence and component confirmation data
- Battlefield/Communication Interface Guide
- Basic operation check procedure
- Consultation tailored to your class schedule
It is suitable for education and PBL classes where student participation is important.
Install the desired sensor
We confirm basic operation before delivery.
After confirming the research goals and equipment, the necessary sensors, controllers, and upper structures are reflected and provided after basic operation tests.
- Negotiation on installing sensors and computing devices
- Mechanism/Electronic Interface Configuration
- Check basic steering/driving behavior
- Document delivery configuration and check items
It is suitable for laboratories that want to focus on algorithms and experimental design immediately after introducing the equipment.
CONFIGURABLE PLATFORMSensors appropriate to the research topic and
Sensors appropriate to the research topic and
Configure upper equipment.
The items below are scalable examples. It is not a basic item, but is confirmed separately after checking the purpose of introduction, budget, and equipment owned.
LIDAR
Mapping, location estimation, obstacle recognition research
camera
RGB, depth, and stereo-based recognition and data collection
Inertial/Driving Sensor
IMU, encoder and odometry fusion experiment
Computing/communication
Research computer, controller and network configuration
Robotic arm/actuator
Combination of single/multiple robot arms and work devices
Safety/superstructure
Switches, protection and mounting frames tailored to the test environment
4WS MOTION LABChanging the steering pattern
Verify control logic.
Verify control logic.
straight aheaddiagonal movementrotate in placepath following
UNIVERSITY USE CASESinto one platform
into one platform
Classes and research continue.
The control, navigation, simulation, and manipulation flows covered by the open technology ecosystem of ROS 2, Nav2, Gazebo, and MoveIt can be tailored to university projects.
Steering/Driving Control
Vehicle kinematics, path following, attitude control and controller comparison experiments.
Autonomous driving/SLAM
Map creation, location estimation and obstacle avoidance using lidar and cameras.
sensor fusion
Time synchronization and state estimation of IMU, encoder, and distance/image sensors.
mobile manipulation
Work planning and coordination of mobile base and single/multiple robot arms.
Simulation-actual vehicle connection
Step-by-step verification of models and control strategies created in a virtual environment in the real world.
Capstone·PBL
The mechanism, battlefield, control, and software teams work together to complete one result.
DELIVERY EXPERIENCEIn line with the university scene
In line with the university scene
We have made and delivered it.
Based on our experience manufacturing and supplying mobile research robots to various universities and educational institutions in Korea, we also organize class schedules and inspection methods. The name of the organization and the terms and conditions of the contract are disclosed only within the scope permitted for disclosure.
Check your goals
Class/research topics, exam space and schedule
composition consultation
Direct manufacturing or delivery of sensors and upper equipment
Production/inspection
Verify assembly or basic operation of selected range
data delivery
Check basic technical data and delivery configuration
ASK RODIXFrom the configuration needed for the laboratory
From the configuration needed for the laboratory
We'll sort it out together.
The review will be expedited if you tell us your school/department, research or class purpose, desired introduction time, and required sensors and equipment you have. Detailed specifications and prices will be provided separately after confirmation of requirements.